Unitree G1 (23 DOF)
Robots
Robots / Simulation asset
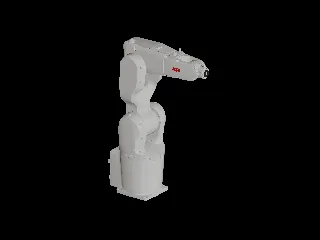
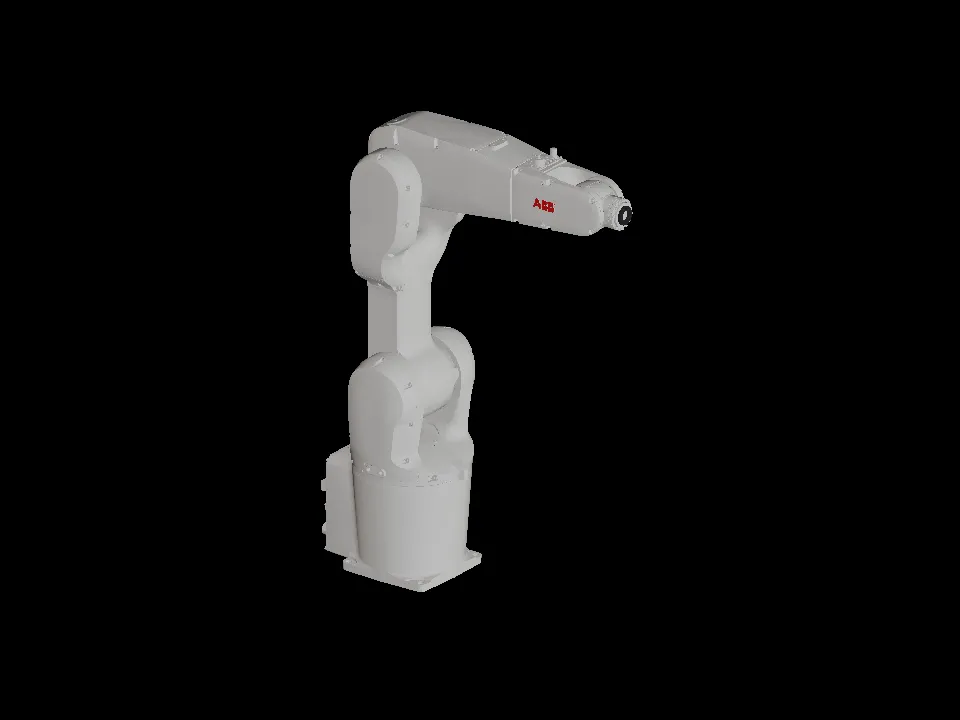
Six-axis robot with a grounded base, position motors and a kinematic robot controller. Tool frame: tool0. Dynamics are estimated; acceleration uses commissioning defaults. ROS-Industrial model, Apache-2.0.
Open asset in editorOpens this asset’s preview in the editor. Sign in and active Simtekton access are required. Add it to your scene when you’re ready.
Use ABB IRB 1200-5/0.9 to build a robot cell, define tool targets and explore joint or linear movements with Simtekton’s robot controller.
Source model: ros-industrial/abb. Distributed under Apache-2.0.
Read license and source notices · Pinned source revision
Original mesh materials, source joint limits and velocities are retained. Dynamics are estimated or uncalibrated; acceleration uses commissioning defaults. Simulation results are not hardware performance guarantees. Model names identify the source hardware; no manufacturer endorsement is implied.