Booster K1
Robots
Robots / Simulation asset
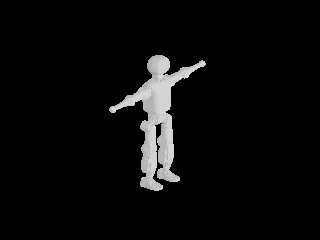
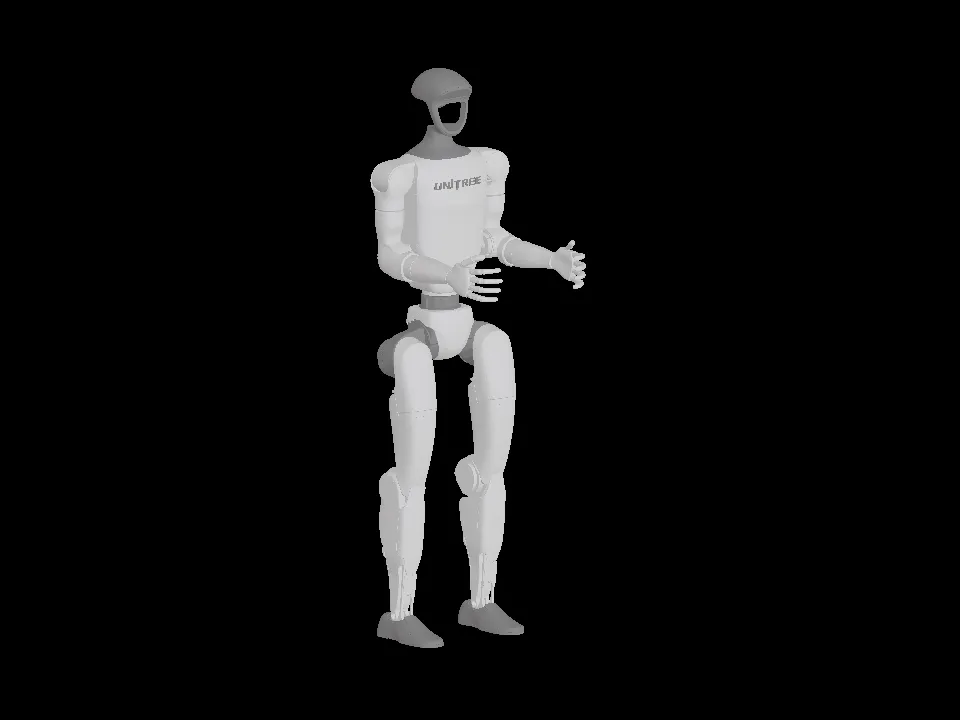
23-joint humanoid with original contrasting dark and light source materials, normals and joint limits. Grounded kinematic RobotController for posing; no walking or balance controller. BSD-3-Clause.
Open asset in editorOpens this asset’s preview in the editor. Sign in and active Simtekton access are required. Add it to your scene when you’re ready.
Use Unitree G1 (23 DOF) to build a robot cell, define tool targets and explore joint or linear movements with Simtekton’s robot controller.
Source model: unitreerobotics/unitree_ros. Distributed under BSD-3-Clause.
Read license and source notices · Pinned source revision
Original mesh materials, source joint limits and velocities are retained. Dynamics are estimated or uncalibrated; acceleration uses commissioning defaults. Simulation results are not hardware performance guarantees. Model names identify the source hardware; no manufacturer endorsement is implied.